Ground truth for Physical AI.

A live, shared spatial model of the work cell.
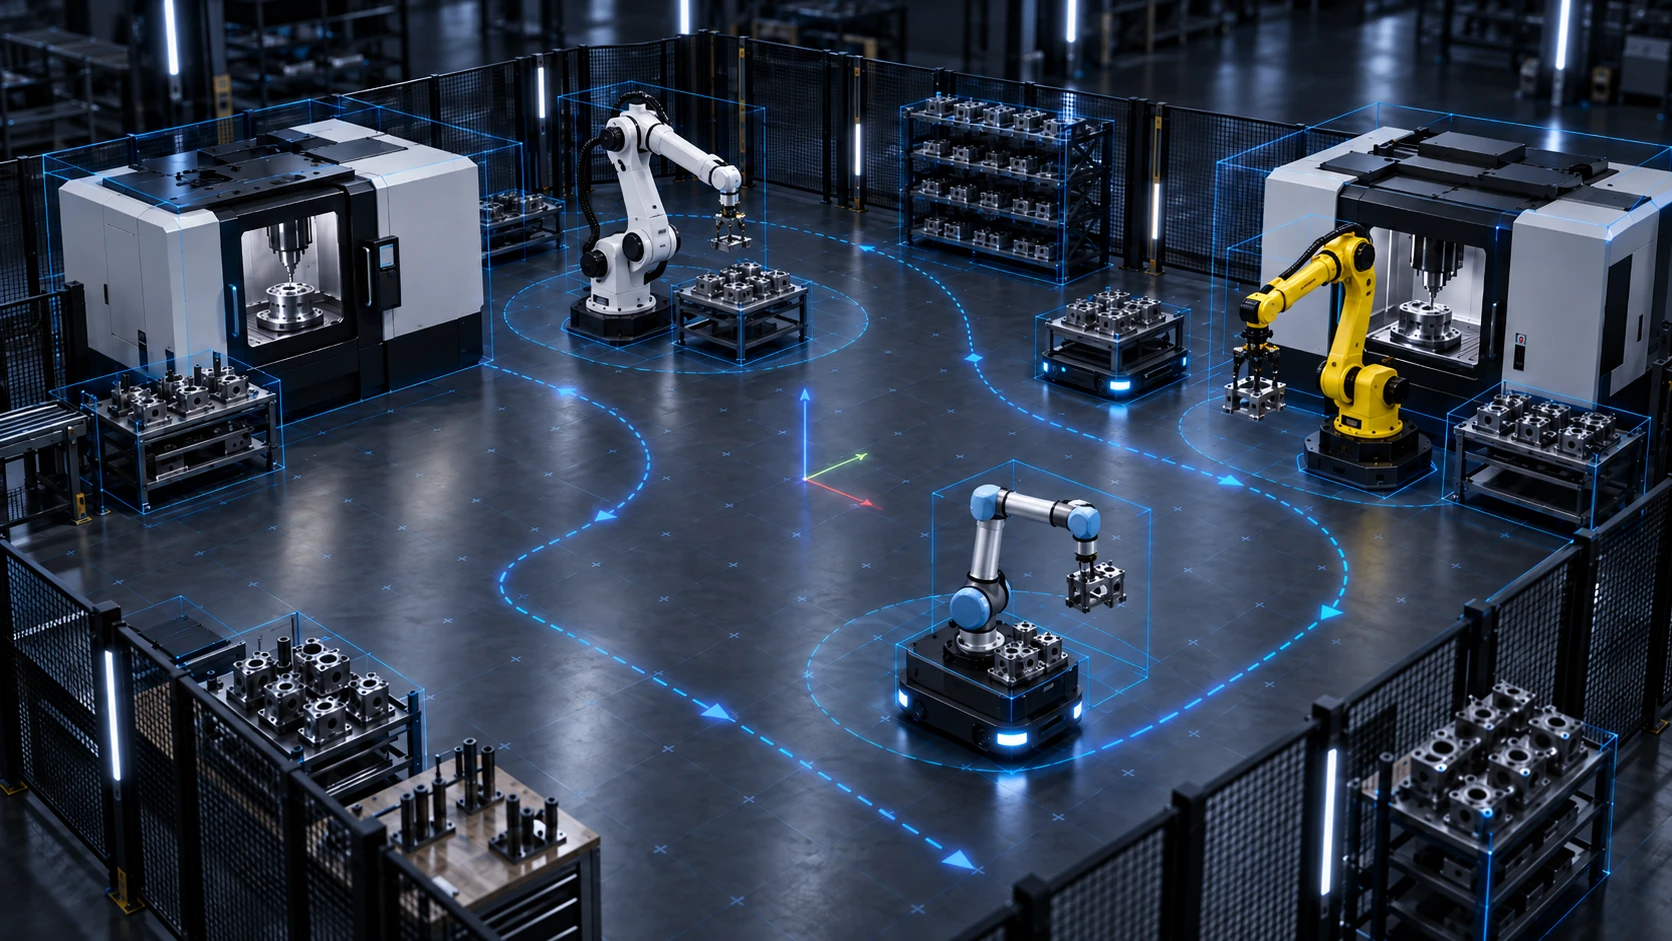
Humatics shared work cell spatial view
God Mode visual placeholderentire work cell · multiple robots · AMRs · machines · moving assets · one spatial frame
Every tracked asset. Identified in 6DOF. Updated at 120 Hz.

Different machines.
Different vendors.
One live guidance layer.

Robots, AMRs, machines, and moving assets can be coordinated in real time across a common spatial frame—even when they don’t natively communicate with one another.
Shared awareness.
Coordinated autonomy.

As machines become more autonomous, coordination requires more than knowing their own position.

Humatics gives every participating machine the same spatial reference—what is in the work cell, where it is, how it is moving, and where everything is relative to everything else.

IDENTIFIED what it is Persistent asset identity
6DOF where it is Position + orientation
120 HZ how it is moving Continuously updated motion state
ONE FRAME relative position to other assets A shared spatial reference across the work cell

One spatial truth,
from sim to real.

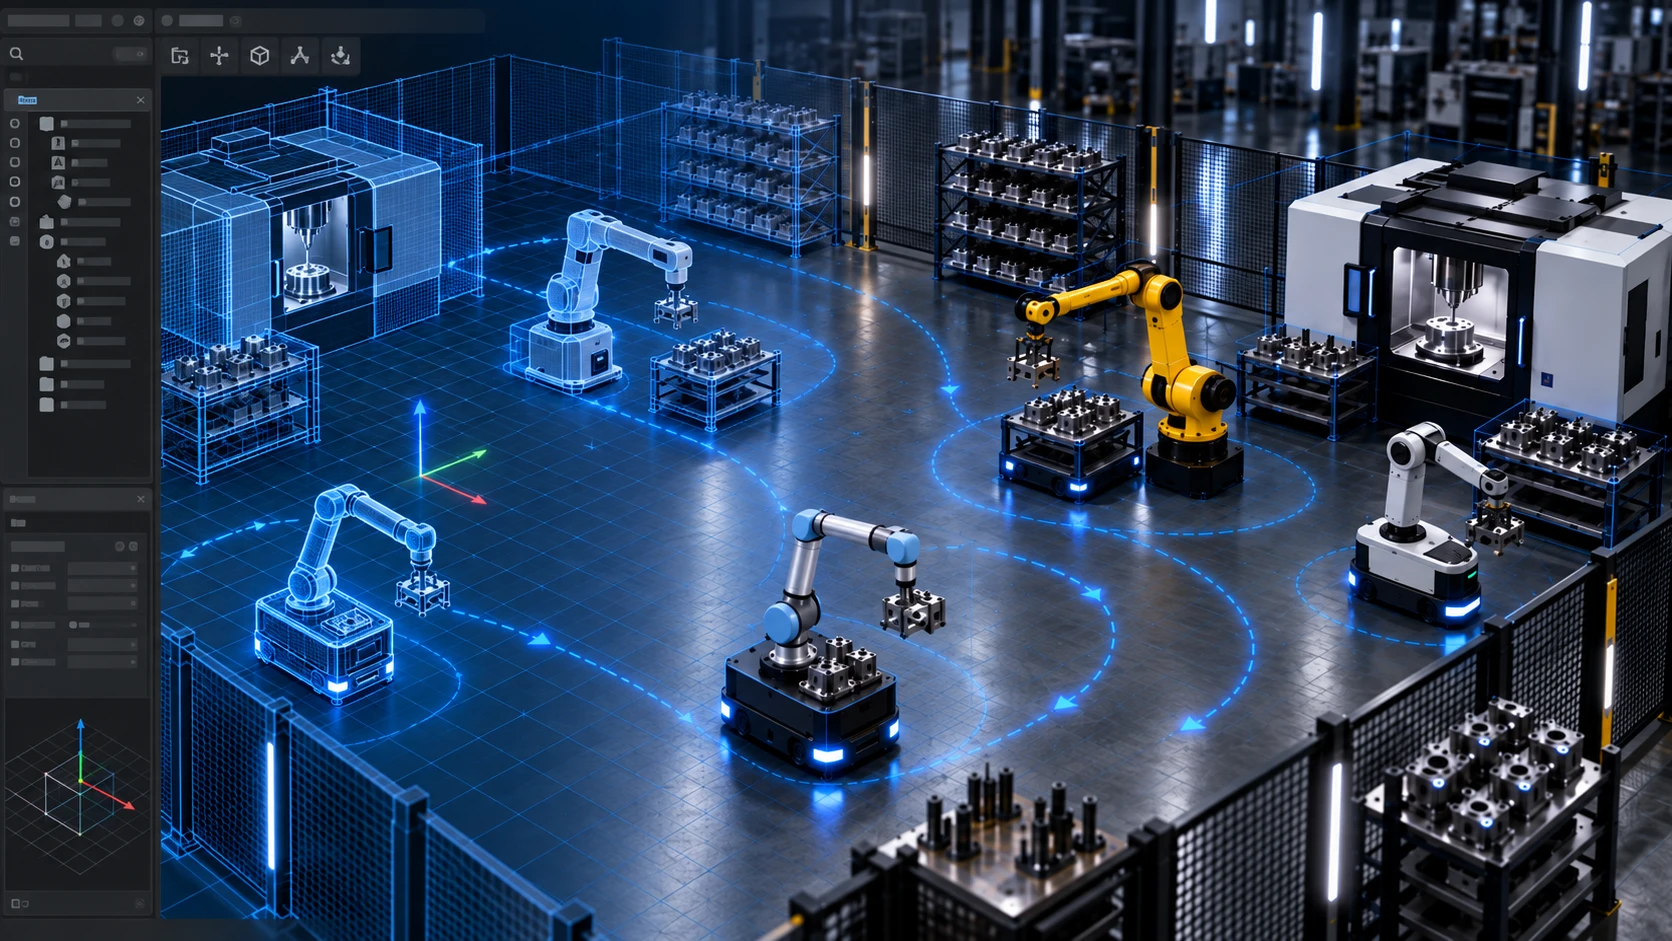
The same spatial reference can carry across the full Physical AI lifecycle—from virtual environments into real production.

01

Simulate

Model the work cell and expected behavior in a shared spatial frame.

02

Train

Use structured spatial data to develop and refine intelligent systems.

03

Deploy

Coordinate heterogeneous robots and moving assets in live production.

04

Measure

Compare intended position and motion with what actually happened.

05

Improve

Feed real-world results back into the next iteration of the system.

Simulated and measured robot pose comparison
Sim ↔ Real visual placeholderexpected trajectory / pose compared with measured physical trajectory / pose

Humatics spatial data supports every phase of the loop. One spatial reference across simulation and reality.

Bring ground truth
to the work cell.

See Humatics in action →